
Litian Gong 「龚利天」
Hi there! I am Litian Gong (龚利天), a Ph.D. student in Electrical Engineering at the University of California, Riverside (Sep 2026 – present), advised by Prof. Jiachen Li. I am a member of the Trustworthy Autonomous Systems Lab (TASL).
I am also a student research intern at the Learning and Interactive Robot Autonomy Lab (LIRA) at USC, working with Prof. Erdem Bıyık.
I completed my M.S. in Electrical Engineering at UC Riverside and received my B.E. in Electrical Engineering from Huazhong University of Science and Technology (HUST), where I worked with Prof. Shaorong Wang.
My research focuses on building embodied intelligent agents that learn robust, generalizable behaviors from data and interaction. I work at the intersection of scalable robot learning frameworks, imitation and reinforcement learning, and visual-language models for long-horizon decision making. My goal is to enable agents to reason over multimodal observations, acquire manipulation and navigation skills efficiently, bridge the sim-to-real gap for real-world autonomous systems, and develop data-efficient, generalizable learning algorithms.
News
- One paper accepted to NeurIPS 2026: Agents' Last Exam.
- One paper accepted to NeurIPS 2026: LIBERO-PeRM: Benchmarking Personalized Robotic Manipulation.
- One paper accepted to CoRL 2026: PACER: Process-Aware VLA Policy Learning from Human Corrections for Robotic Disassembly.
- Started the Ph.D. program in Electrical Engineering at UC Riverside, advised by Prof. Jiachen Li.
- One paper accepted to CVPR 2026: ORIC: Benchmarking Object Recognition in Incongruous Context for Large Vision-Language Models.
- One paper accepted to ICRA 2026: AutoFocus-IL: VLM-based Saliency Maps for Data-Efficient Visual Imitation Learning without Extra Human Annotations.
- Joined the LIRA Lab at USC, working with Prof. Erdem Bıyık.
- Started research at TASL, UC Riverside, working with Prof. Jiachen Li.
- Started Master's program in Electrical Engineering at UC Riverside.
- Graduated from HUST as Outstanding Undergraduate Graduate.
Education
- Ph.D., Electrical Engineering, University of California, Riverside (Sep 2026 – Present). Advisor: Prof. Jiachen Li.
- M.S., Electrical Engineering, University of California, Riverside (Sep 2024 – Jun 2026). Advisor: Prof. Jiachen Li.
- B.E., Electrical Engineering, Huazhong University of Science and Technology (HUST) (Sep 2020 – Jun 2024).
Publications
* Equal contribution.
In submission
Conference on Neural Information Processing Systems (NeurIPS), 2026
project page arXiv code ★ 7
Conference on Neural Information Processing Systems (NeurIPS), 2026
project page arXiv code ★ 1.2k
Conference on Robot Learning (CoRL), 2026
project page arXiv code ★ 1
IEEE International Conference on Robotics and Automation (ICRA), 2026
project page arXiv code ★ 5
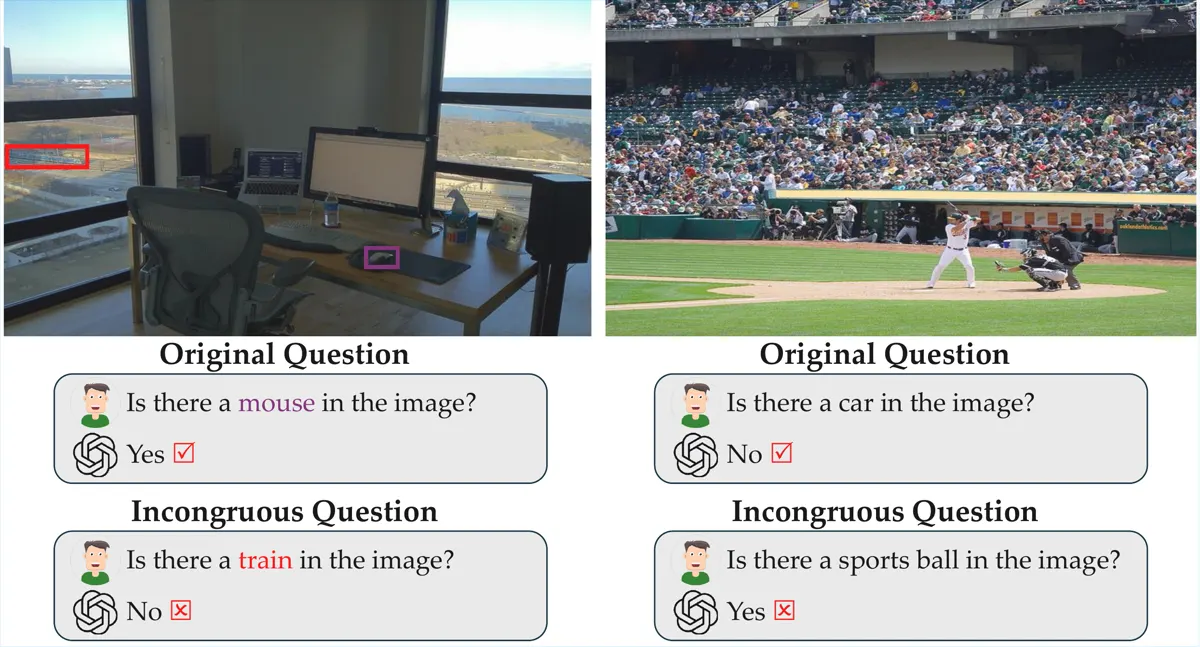
IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2026
arXiv code ★ 2
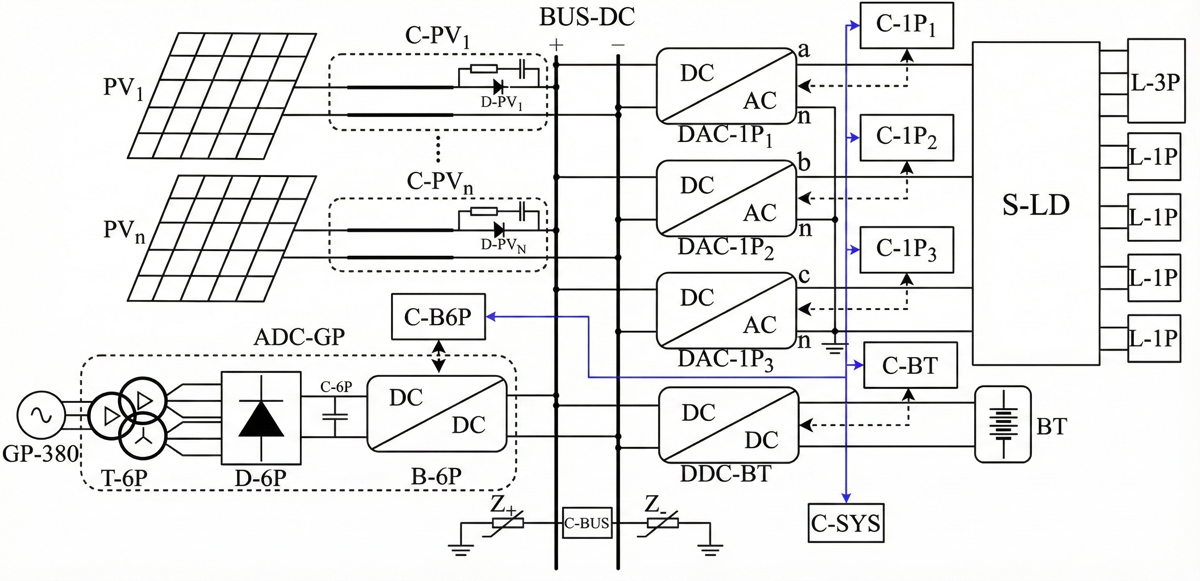
IEEE International Conference on New Energy and Power Engineering (ICNEPE), 2023
DOI
Projects
A sim-to-real pipeline for vision-language-action (VLA) models. We align a simulated DROID-style Franka setup with the real robot (controller, cameras, lab scene), render RL expert trajectories in simulation for distillation into π0.5-DROID, and LoRA-fine-tune π0.5 on real Franka FR3 data with out-of-distribution real-robot evaluation.
A controlled study of memory mechanisms for robot policies: published memory designs are re-implemented as plug-in modules on one shared Diffusion Policy backbone and evaluated under the same benchmark and protocol, including ablations where the policy's memory is masked, shuffled, or zeroed.
A modular world-model framework that breaks down design choices from driving, manipulation, and navigation world models into swappable components for controlled comparison. A learned latent world model is used as the internal simulator for model-predictive control in CarRacing (left: real environment, right: imagined future frames).
Learning-based person following for mobile robots, from a Unitree Go2-W wheeled quadruped to a Rosmaster X3 omnidirectional car. We build Isaac Sim / Isaac Lab environments with simulated humans and RTX lidar, replay real-robot runs as closed-loop digital twins running the real perception and decision stack, and train terrain-aware following policies on 3D street scenes.
Visitors
Visitor map unavailable.